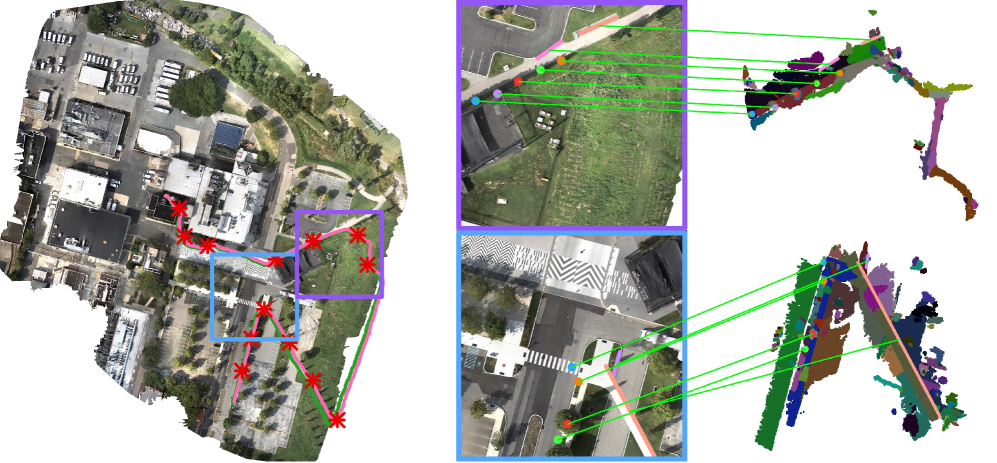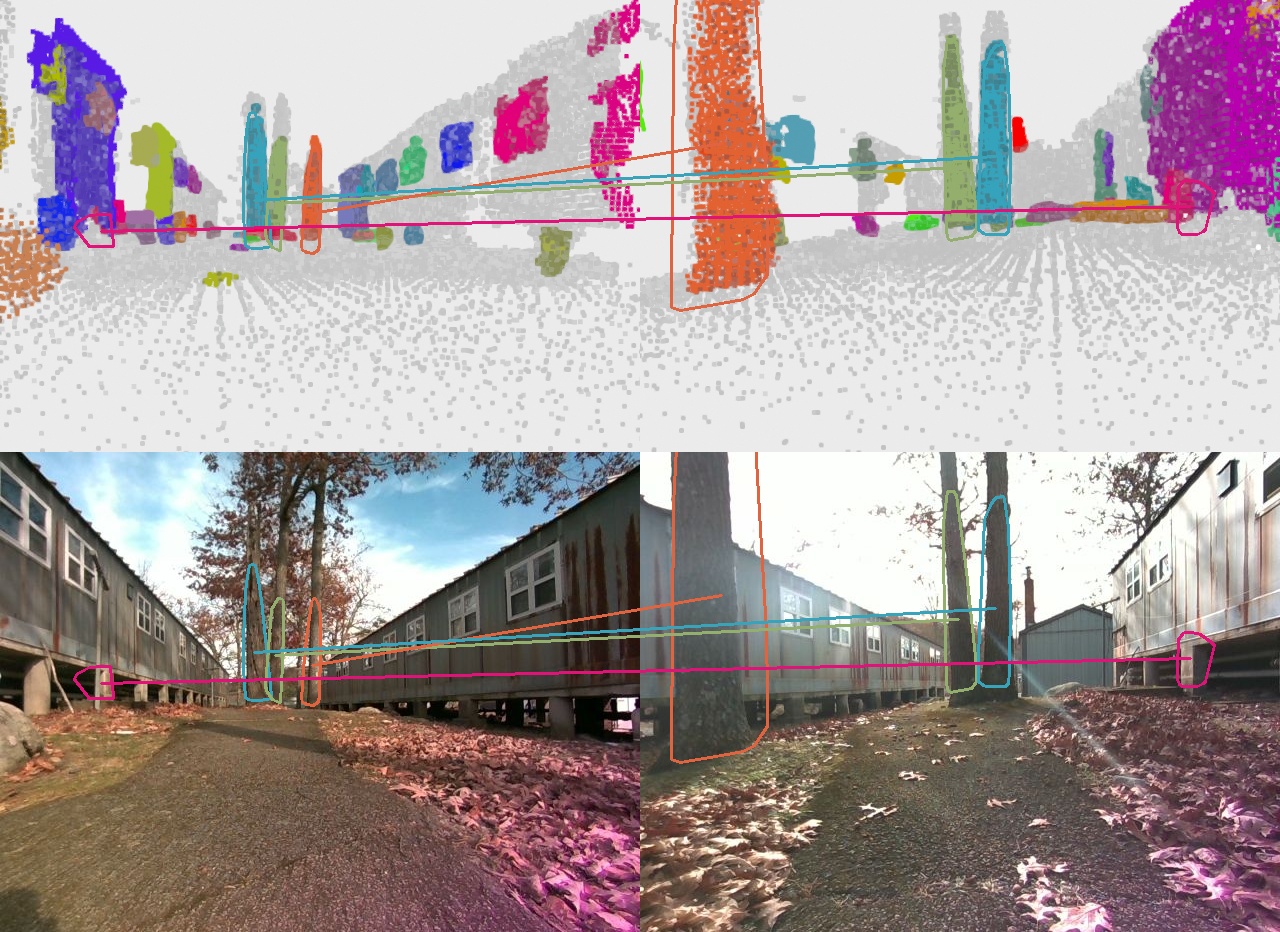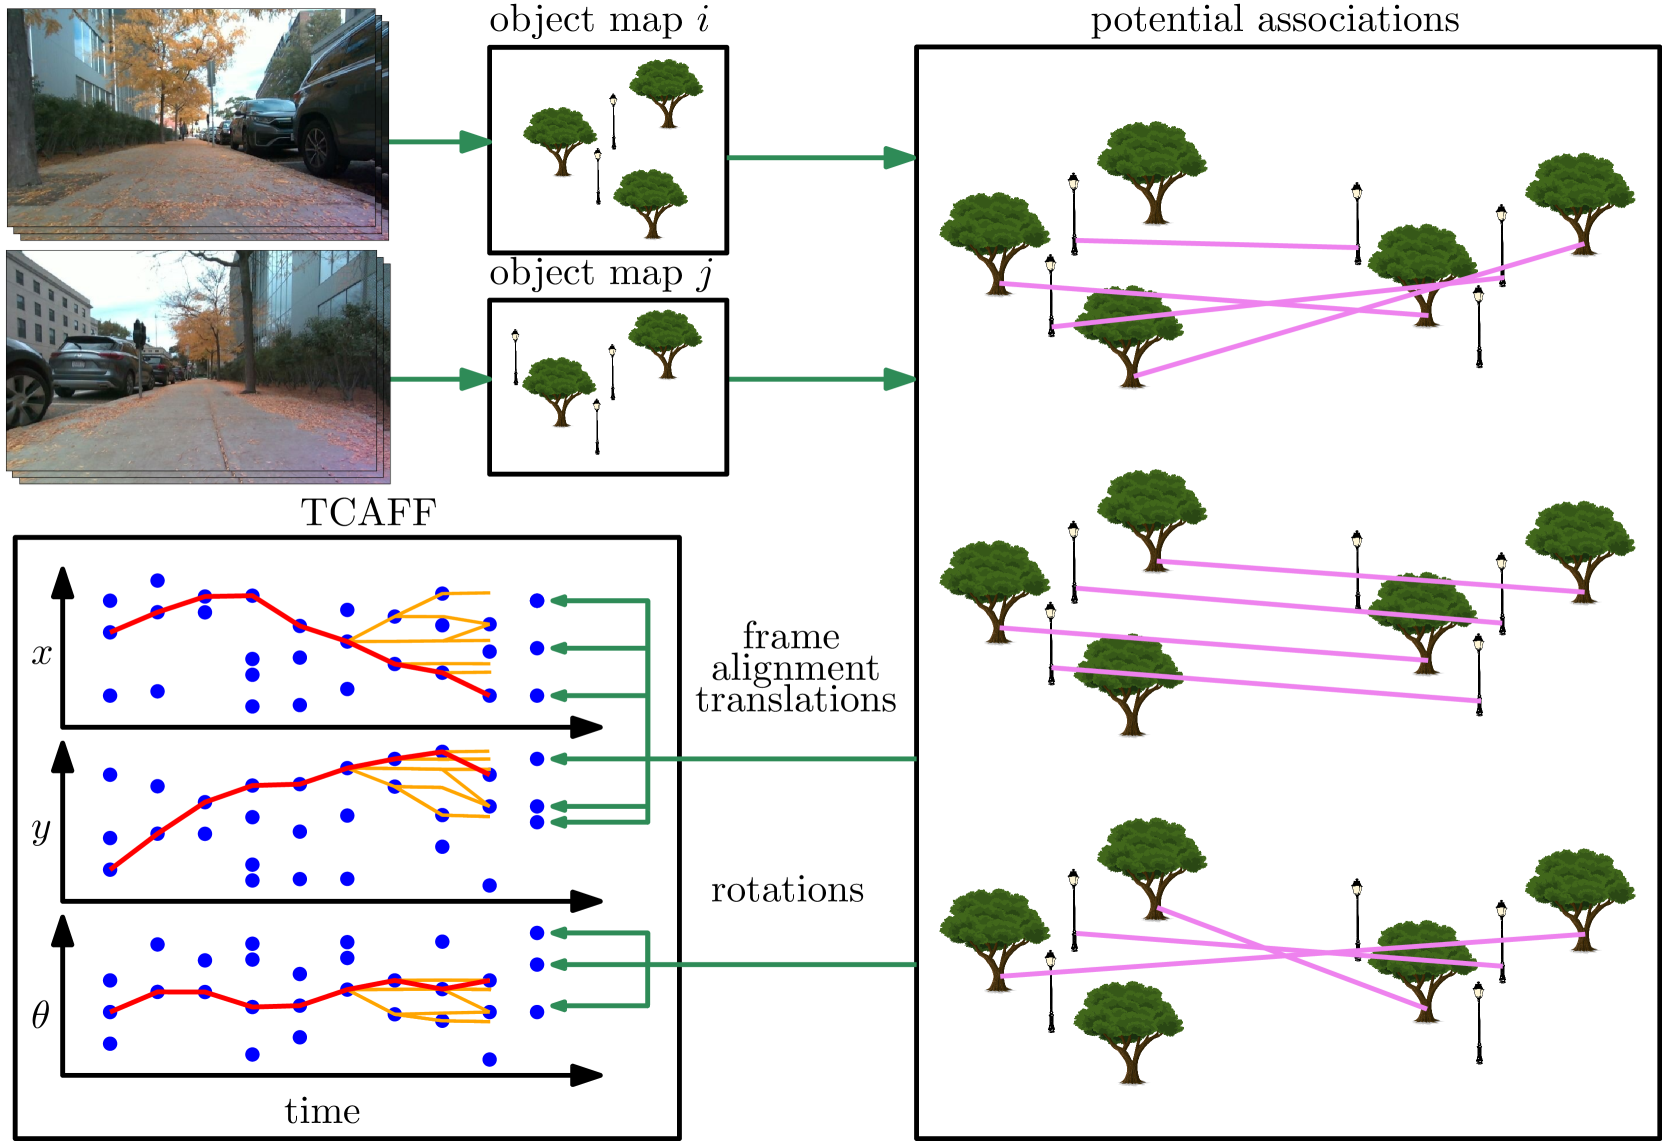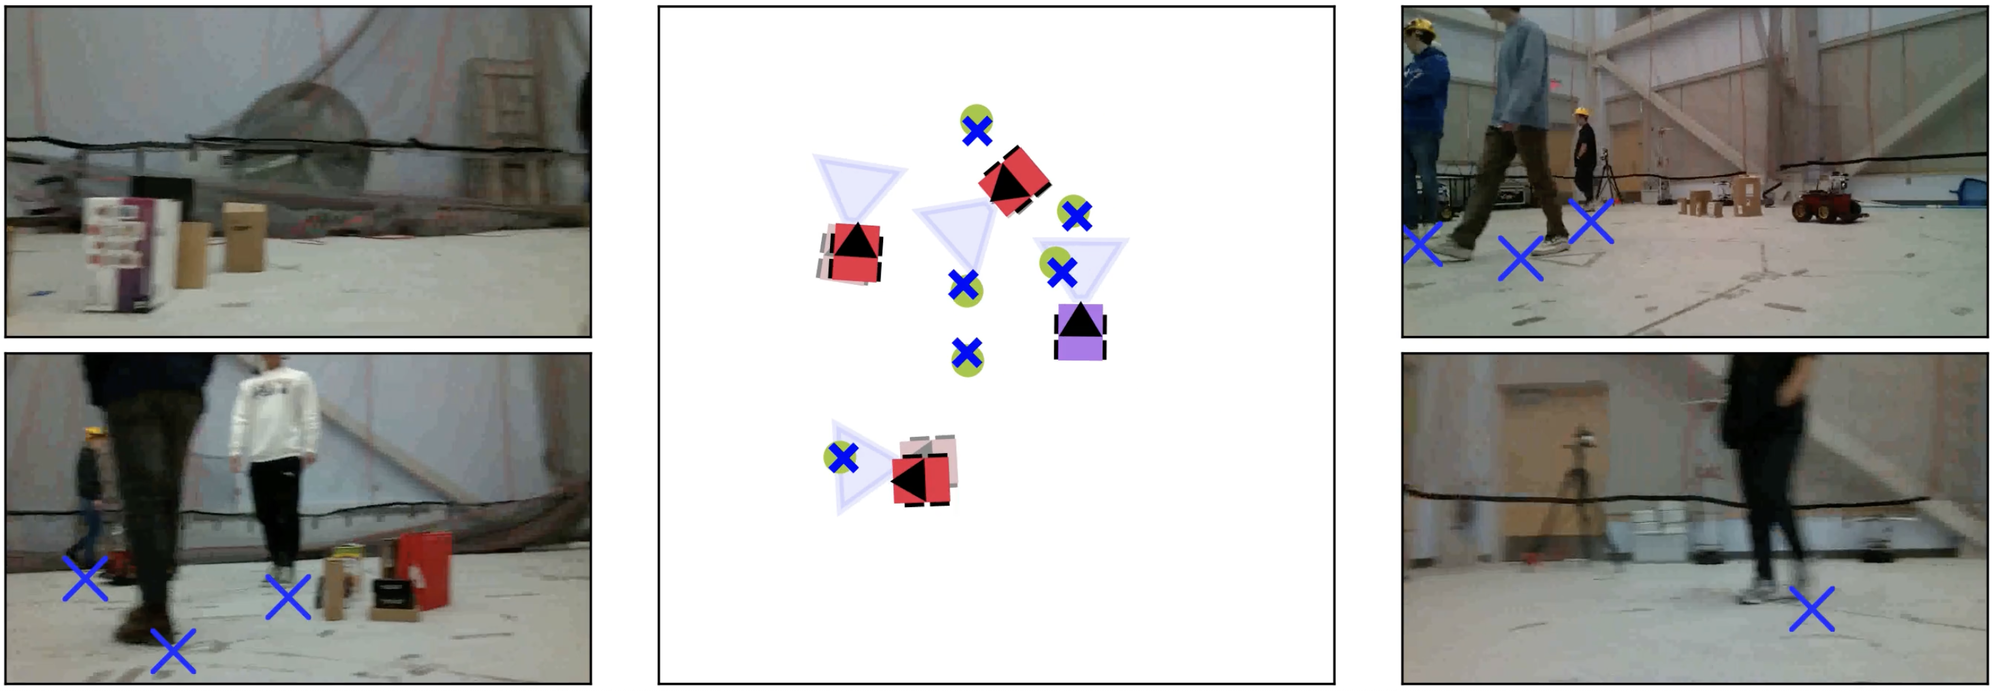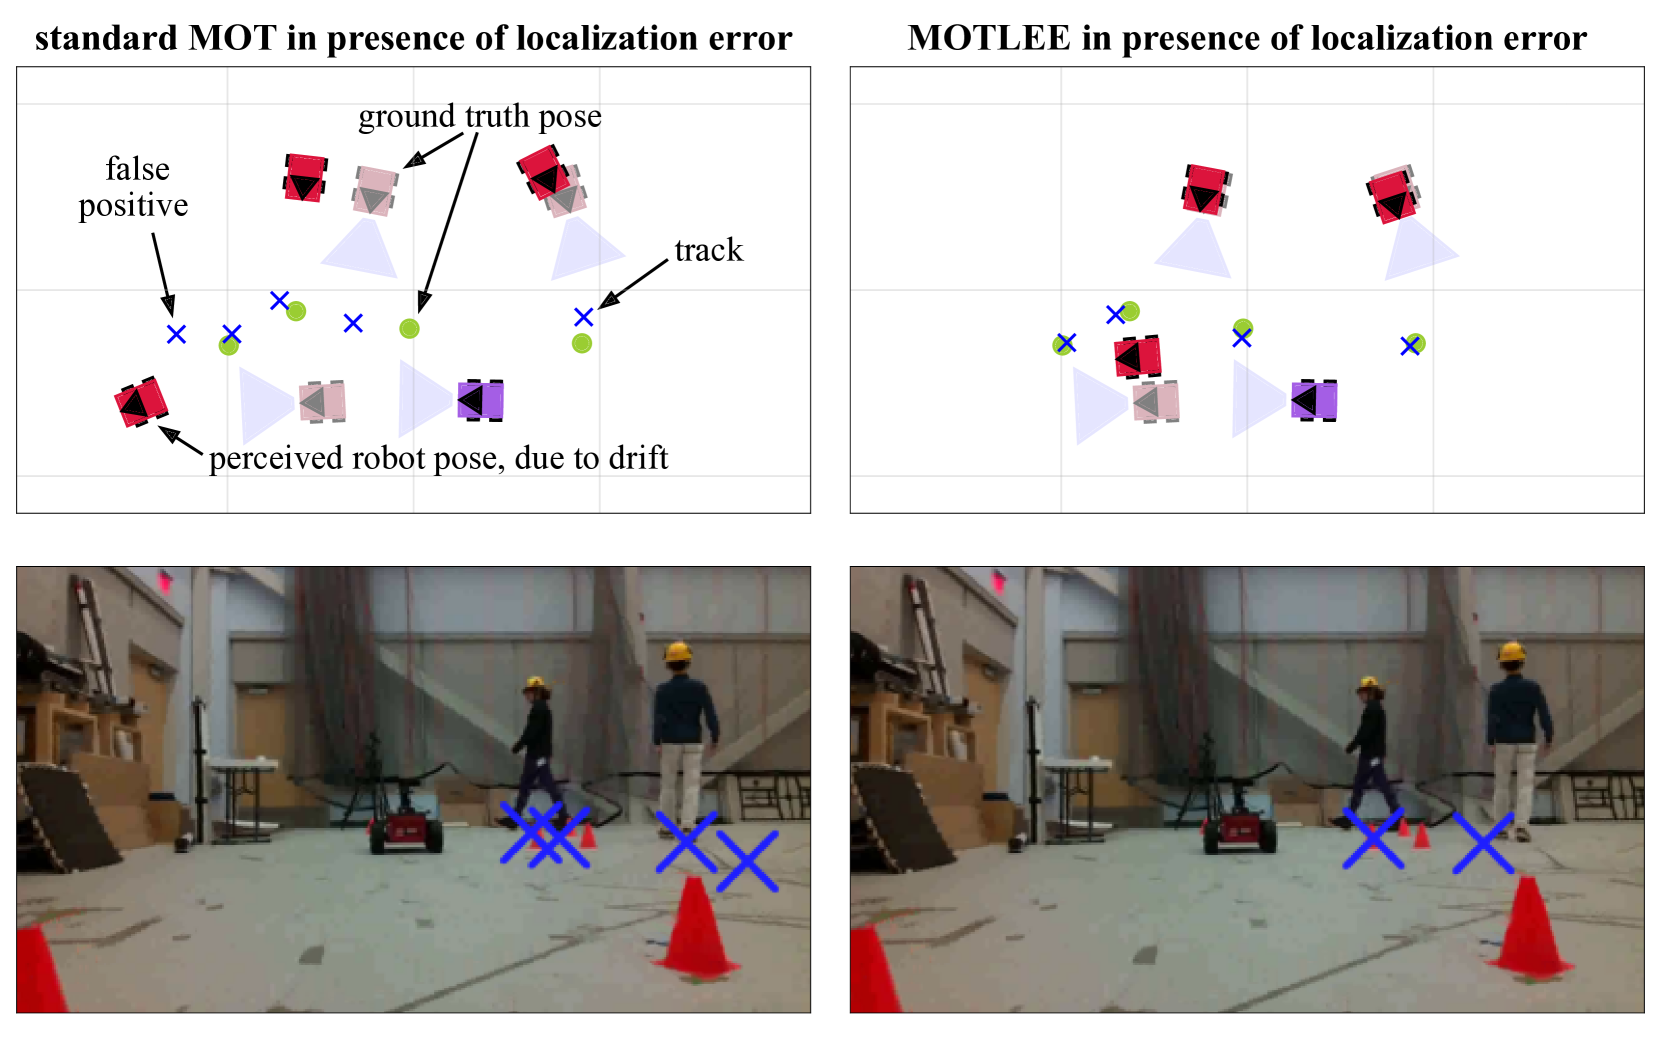
I am a PhD student at MIT. I am passionate about multi-robot localization and perception work that enables robots to accurately and efficiently understand their world, particularly for enabling downstream decision-making. I believe that research should be rooted in solving real problems, so my work focuses on developing scalable algorithms that show improved performance on real robots.
I am a part of the Aerospace Controls Lab (ACL) at MIT and am advised by Professor Jonathan How. Before starting my PhD, I received my SM degree also doing research in the ACL in 2024 and received my Bachelor’s in Computer Engineering at Brigham Young University.