Software

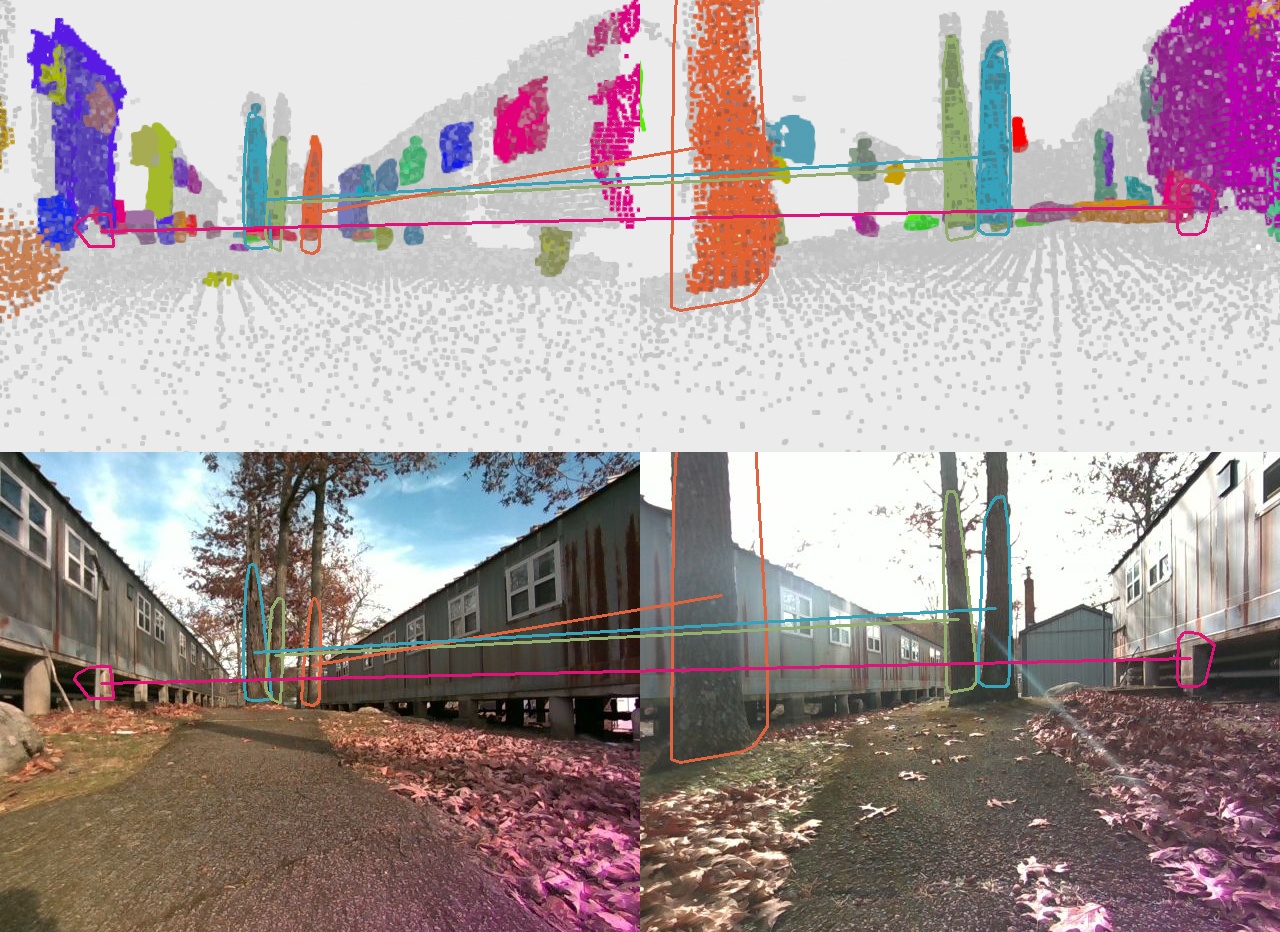
ROMAN

View-invariant global localization method that matches open-set objects across different robot viewpoints for reliable pose estimation, even when a scene is observed from opposite directions.

Code     Website    

Meridian

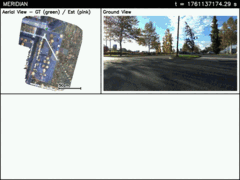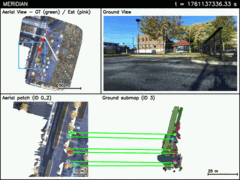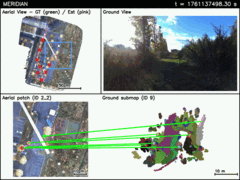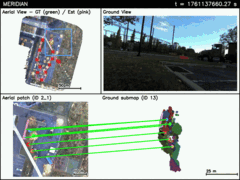
Localizes a ground robot from aerial ortho-imagery, providing meter-level pose estimates without any initial pose information or environmental fine-tuning.

Code    

robotdatapy

Python package designed to make accessing and manipulating robot and geometric data easy.

Code    

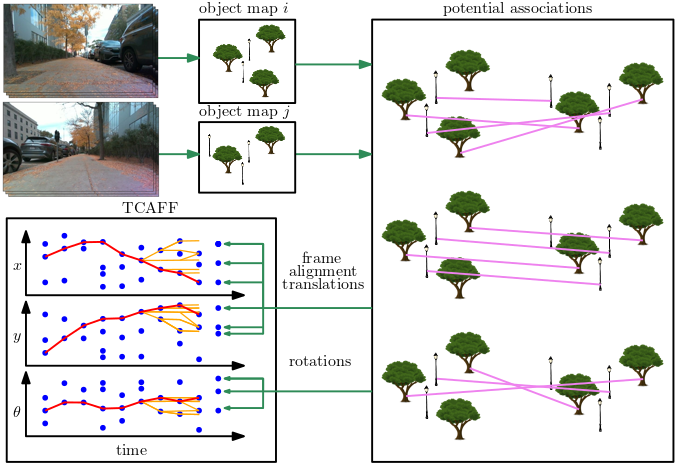
TCAFF

Multiple hypothesis algorithm for temporally consistent alignment of coordinate frames between collaborative robots.

Code    

Quadplane Project

Trajectory tracking simulation and controller for eVTOL quadplane vehicles, including low-level control allocation and dynamics modeling.

Code     Video